Geant4.10
 All Data Structures Namespaces Files Functions Variables Typedefs Enumerations Enumerator Friends Macros Groups Pages
Public Member Functions | Protected Member Functions | Protected Attributes
G4ReflectedSolid Class Reference

#include <G4ReflectedSolid.hh>

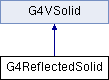
Inheritance diagram for G4ReflectedSolid:
G4VSolid

Public Member Functions

 G4ReflectedSolid (const G4String &pName, G4VSolid *pSolid, const G4Transform3D &transform)
 
virtual ~G4ReflectedSolid ()
 
EInside Inside (const G4ThreeVector &p) const
 
G4bool CalculateExtent (const EAxis pAxis, const G4VoxelLimits &pVoxelLimit, const G4AffineTransform &pTransform, G4double &pMin, G4double &pMax) const
 
G4ThreeVector SurfaceNormal (const G4ThreeVector &p) const
 
G4double DistanceToIn (const G4ThreeVector &p, const G4ThreeVector &v) const
 
G4double DistanceToIn (const G4ThreeVector &p) const
 
G4double DistanceToOut (const G4ThreeVector &p, const G4ThreeVector &v, const G4bool calcNorm=false, G4bool *validNorm=0, G4ThreeVector *n=0) const
 
G4double DistanceToOut (const G4ThreeVector &p) const
 
void ComputeDimensions (G4VPVParameterisation *p, const G4int n, const G4VPhysicalVolume *pRep)
 
G4ThreeVector GetPointOnSurface () const
 
G4VSolid * Clone () const
 
virtual G4GeometryType GetEntityType () const
 
virtual const G4ReflectedSolid * GetReflectedSolidPtr () const
 
virtual G4ReflectedSolid * GetReflectedSolidPtr ()
 
G4VSolid * GetConstituentMovedSolid () const
 
G4Transform3D GetTransform3D () const
 
void SetTransform3D (G4Transform3D &)
 
G4Transform3D GetDirectTransform3D () const
 
void SetDirectTransform3D (G4Transform3D &)
 
std::ostream & StreamInfo (std::ostream &os) const
 
 G4ReflectedSolid (const G4ReflectedSolid &rhs)
 
G4ReflectedSolid & operator= (const G4ReflectedSolid &rhs)
 
void DescribeYourselfTo (G4VGraphicsScene &scene) const
 
G4Polyhedron * CreatePolyhedron () const
 
G4Polyhedron * GetPolyhedron () const
 
- Public Member Functions inherited from G4VSolid
 G4VSolid (const G4String &name)
 
virtual ~G4VSolid ()
 
G4bool operator== (const G4VSolid &s) const
 
G4String GetName () const
 
void SetName (const G4String &name)
 
G4double GetTolerance () const
 
virtual G4double GetCubicVolume ()
 
virtual G4double GetSurfaceArea ()
 
void DumpInfo () const
 
virtual G4VisExtent GetExtent () const
 
virtual const G4VSolid * GetConstituentSolid (G4int no) const
 
virtual G4VSolid * GetConstituentSolid (G4int no)
 
virtual const G4DisplacedSolid * GetDisplacedSolidPtr () const
 
virtual G4DisplacedSolid * GetDisplacedSolidPtr ()
 
 G4VSolid (__void__ &)
 
 G4VSolid (const G4VSolid &rhs)
 
G4VSolid & operator= (const G4VSolid &rhs)
 

Protected Member Functions

G4AffineTransform GetTransform () const
 
void SetTransform (G4AffineTransform &)
 
G4AffineTransform GetDirectTransform () const
 
void SetDirectTransform (G4AffineTransform &)
 
G4RotationMatrix GetFrameRotation () const
 
void SetFrameRotation (const G4RotationMatrix &)
 
G4ThreeVector GetFrameTranslation () const
 
void SetFrameTranslation (const G4ThreeVector &)
 
G4RotationMatrix GetObjectRotation () const
 
void SetObjectRotation (const G4RotationMatrix &)
 
G4ThreeVector GetObjectTranslation () const
 
void SetObjectTranslation (const G4ThreeVector &)
 
- Protected Member Functions inherited from G4VSolid
void CalculateClippedPolygonExtent (G4ThreeVectorList &pPolygon, const G4VoxelLimits &pVoxelLimit, const EAxis pAxis, G4double &pMin, G4double &pMax) const
 
void ClipCrossSection (G4ThreeVectorList *pVertices, const G4int pSectionIndex, const G4VoxelLimits &pVoxelLimit, const EAxis pAxis, G4double &pMin, G4double &pMax) const
 
void ClipBetweenSections (G4ThreeVectorList *pVertices, const G4int pSectionIndex, const G4VoxelLimits &pVoxelLimit, const EAxis pAxis, G4double &pMin, G4double &pMax) const
 
void ClipPolygon (G4ThreeVectorList &pPolygon, const G4VoxelLimits &pVoxelLimit, const EAxis pAxis) const
 
G4double EstimateCubicVolume (G4int nStat, G4double epsilon) const
 
G4double EstimateSurfaceArea (G4int nStat, G4double ell) const
 

Protected Attributes

G4VSolid * fPtrSolid
 
G4AffineTransform * fPtrTransform
 
G4AffineTransform * fDirectTransform
 
G4Transform3D * fPtrTransform3D
 
G4Transform3D * fDirectTransform3D
 
G4Polyhedron * fpPolyhedron
 
- Protected Attributes inherited from G4VSolid
G4double kCarTolerance
 

Detailed Description

Definition at line 51 of file G4ReflectedSolid.hh.

Constructor & Destructor Documentation

G4ReflectedSolid::G4ReflectedSolid ( const G4String &  pName,
G4VSolid *  pSolid,
const G4Transform3D &  transform 
)

Definition at line 56 of file G4ReflectedSolid.cc.

References fDirectTransform, fDirectTransform3D, fPtrSolid, fPtrTransform, fPtrTransform3D, HepGeom::Transform3D::getTranslation(), HepGeom::Transform3D::inverse(), and G4AffineTransform::Invert().

Referenced by Clone().

59  : G4VSolid(pName), fpPolyhedron(0)
60 {
61  fPtrSolid = pSolid ;
62  G4RotationMatrix rotMatrix ;
63 
65  new G4AffineTransform(rotMatrix, transform.getTranslation()) ;
67  new G4AffineTransform(rotMatrix, transform.getTranslation()) ;
68  fPtrTransform->Invert() ;
69 
70  fDirectTransform3D = new G4Transform3D(transform) ;
71  fPtrTransform3D = new G4Transform3D(transform.inverse()) ;
72 }
Transform3D inverse() const
Definition: Transform3D.cc:142
G4Transform3D * fDirectTransform3D
G4AffineTransform * fDirectTransform
G4AffineTransform & Invert()
G4Transform3D * fPtrTransform3D
HepGeom::Transform3D G4Transform3D
G4AffineTransform * fPtrTransform
G4Polyhedron * fpPolyhedron
G4VSolid(const G4String &name)
Definition: G4VSolid.cc:60
CLHEP::Hep3Vector getTranslation() const
G4ReflectedSolid::~G4ReflectedSolid ( )
virtual

Definition at line 77 of file G4ReflectedSolid.cc.

References fDirectTransform, fDirectTransform3D, fpPolyhedron, fPtrTransform, and fPtrTransform3D.

78 {
79  if(fPtrTransform)
80  {
81  delete fPtrTransform; fPtrTransform=0;
83  }
84  if(fPtrTransform3D)
85  {
88  }
89  delete fpPolyhedron;
90 }
G4Transform3D * fDirectTransform3D
G4AffineTransform * fDirectTransform
G4Transform3D * fPtrTransform3D
G4AffineTransform * fPtrTransform
G4Polyhedron * fpPolyhedron
G4ReflectedSolid::G4ReflectedSolid ( const G4ReflectedSolid &  rhs)

Definition at line 95 of file G4ReflectedSolid.cc.

References fDirectTransform, fDirectTransform3D, fPtrTransform, and fPtrTransform3D.

96  : G4VSolid(rhs), fPtrSolid(rhs.fPtrSolid), fpPolyhedron(0)
97 {
102 }
G4Transform3D * fDirectTransform3D
G4AffineTransform * fDirectTransform
G4Transform3D * fPtrTransform3D
HepGeom::Transform3D G4Transform3D
G4AffineTransform * fPtrTransform
G4Polyhedron * fpPolyhedron
G4VSolid(const G4String &name)
Definition: G4VSolid.cc:60

Member Function Documentation

G4bool G4ReflectedSolid::CalculateExtent ( const EAxis  pAxis,
const G4VoxelLimits &  pVoxelLimit,
const G4AffineTransform &  pTransform,
G4double &  pMin,
G4double &  pMax 
) const
virtual

Implements G4VSolid.

Definition at line 266 of file G4ReflectedSolid.cc.

References G4VSolid::CalculateExtent(), G4VSolid::ClipBetweenSections(), G4VSolid::ClipCrossSection(), G4VSolid::DumpInfo(), FatalException, fPtrSolid, G4Exception(), G4VoxelLimits::GetMaxExtent(), G4VoxelLimits::GetMaxXExtent(), G4VoxelLimits::GetMaxYExtent(), G4VoxelLimits::GetMaxZExtent(), G4VoxelLimits::GetMinExtent(), G4VoxelLimits::GetMinXExtent(), G4VoxelLimits::GetMinYExtent(), G4VoxelLimits::GetMinZExtent(), Inside(), CLHEP::HepRotation::inverse(), G4VoxelLimits::IsLimited(), G4VSolid::kCarTolerance, kOutside, kXAxis, kYAxis, kZAxis, G4AffineTransform::NetRotation(), G4AffineTransform::NetTranslation(), HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

271 {
272 
273  G4VoxelLimits unLimit;
274  G4AffineTransform unTransform;
275 
276  G4double x1 = -kInfinity, x2 = kInfinity,
277  y1 = -kInfinity, y2 = kInfinity,
278  z1 = -kInfinity, z2 = kInfinity;
279 
280  G4bool existsAfterClip = false ;
281  existsAfterClip =
282  fPtrSolid->CalculateExtent(kXAxis,unLimit,unTransform,x1,x2);
283  existsAfterClip =
284  fPtrSolid->CalculateExtent(kYAxis,unLimit,unTransform,y1,y2);
285  existsAfterClip =
286  fPtrSolid->CalculateExtent(kZAxis,unLimit,unTransform,z1,z2);
287 
288  existsAfterClip = false;
289  pMin = +kInfinity ;
290  pMax = -kInfinity ;
291 
292  G4Transform3D pTransform3D = G4Transform3D(pTransform.NetRotation().inverse(),
293  pTransform.NetTranslation());
294 
295  G4Transform3D transform3D = pTransform3D*(*fDirectTransform3D);
296 
297  G4Point3D tmpPoint;
298 
299  // Calculate rotated vertex coordinates
300 
301  G4ThreeVectorList* vertices = new G4ThreeVectorList();
302 
303  if (vertices)
304  {
305  vertices->reserve(8);
306 
307  G4ThreeVector vertex0(x1,y1,z1) ;
308  tmpPoint = transform3D*G4Point3D(vertex0);
309  vertex0 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
310  vertices->push_back(vertex0);
311 
312  G4ThreeVector vertex1(x2,y1,z1) ;
313  tmpPoint = transform3D*G4Point3D(vertex1);
314  vertex1 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
315  vertices->push_back(vertex1);
316 
317  G4ThreeVector vertex2(x2,y2,z1) ;
318  tmpPoint = transform3D*G4Point3D(vertex2);
319  vertex2 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
320  vertices->push_back(vertex2);
321 
322  G4ThreeVector vertex3(x1,y2,z1) ;
323  tmpPoint = transform3D*G4Point3D(vertex3);
324  vertex3 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
325  vertices->push_back(vertex3);
326 
327  G4ThreeVector vertex4(x1,y1,z2) ;
328  tmpPoint = transform3D*G4Point3D(vertex4);
329  vertex4 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
330  vertices->push_back(vertex4);
331 
332  G4ThreeVector vertex5(x2,y1,z2) ;
333  tmpPoint = transform3D*G4Point3D(vertex5);
334  vertex5 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
335  vertices->push_back(vertex5);
336 
337  G4ThreeVector vertex6(x2,y2,z2) ;
338  tmpPoint = transform3D*G4Point3D(vertex6);
339  vertex6 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
340  vertices->push_back(vertex6);
341 
342  G4ThreeVector vertex7(x1,y2,z2) ;
343  tmpPoint = transform3D*G4Point3D(vertex7);
344  vertex7 = G4ThreeVector(tmpPoint.x(),tmpPoint.y(),tmpPoint.z());
345  vertices->push_back(vertex7);
346  }
347  else
348  {
349  DumpInfo();
350  G4Exception("G4ReflectedSolid::CalculateExtent()",
351  "GeomMgt0003", FatalException,
352  "Error in allocation of vertices. Out of memory !");
353  }
354 
355  ClipCrossSection(vertices,0,pVoxelLimit,pAxis,pMin,pMax) ;
356  ClipCrossSection(vertices,4,pVoxelLimit,pAxis,pMin,pMax) ;
357  ClipBetweenSections(vertices,0,pVoxelLimit,pAxis,pMin,pMax) ;
358 
359  if (pVoxelLimit.IsLimited(pAxis) == false)
360  {
361  if ( pMin != kInfinity || pMax != -kInfinity )
362  {
363  existsAfterClip = true ;
364 
365  // Add 2*tolerance to avoid precision troubles
366 
367  pMin -= kCarTolerance;
368  pMax += kCarTolerance;
369  }
370  }
371  else
372  {
373  G4ThreeVector clipCentre(
374  ( pVoxelLimit.GetMinXExtent()+pVoxelLimit.GetMaxXExtent())*0.5,
375  ( pVoxelLimit.GetMinYExtent()+pVoxelLimit.GetMaxYExtent())*0.5,
376  ( pVoxelLimit.GetMinZExtent()+pVoxelLimit.GetMaxZExtent())*0.5);
377 
378  if ( pMin != kInfinity || pMax != -kInfinity )
379  {
380  existsAfterClip = true ;
381 
382 
383  // Check to see if endpoints are in the solid
384 
385  clipCentre(pAxis) = pVoxelLimit.GetMinExtent(pAxis);
386 
387  if (Inside(transform3D.inverse()*G4Point3D(clipCentre)) != kOutside)
388  {
389  pMin = pVoxelLimit.GetMinExtent(pAxis);
390  }
391  else
392  {
393  pMin -= kCarTolerance;
394  }
395  clipCentre(pAxis) = pVoxelLimit.GetMaxExtent(pAxis);
396 
397  if (Inside(transform3D.inverse()*G4Point3D(clipCentre)) != kOutside)
398  {
399  pMax = pVoxelLimit.GetMaxExtent(pAxis);
400  }
401  else
402  {
403  pMax += kCarTolerance;
404  }
405  }
406  // Check for case where completely enveloping clipping volume
407  // If point inside then we are confident that the solid completely
408  // envelopes the clipping volume. Hence set min/max extents according
409  // to clipping volume extents along the specified axis.
410 
411  else if (Inside(transform3D.inverse()*G4Point3D(clipCentre)) != kOutside)
412  {
413  existsAfterClip = true ;
414  pMin = pVoxelLimit.GetMinExtent(pAxis) ;
415  pMax = pVoxelLimit.GetMaxExtent(pAxis) ;
416  }
417  }
418  delete vertices;
419  return existsAfterClip;
420 }
void ClipCrossSection(G4ThreeVectorList *pVertices, const G4int pSectionIndex, const G4VoxelLimits &pVoxelLimit, const EAxis pAxis, G4double &pMin, G4double &pMax) const
Definition: G4VSolid.cc:347
virtual G4bool CalculateExtent(const EAxis pAxis, const G4VoxelLimits &pVoxelLimit, const G4AffineTransform &pTransform, G4double &pMin, G4double &pMax) const =0
G4double GetMinYExtent() const
CLHEP::Hep3Vector G4ThreeVector
EInside Inside(const G4ThreeVector &p) const
G4ThreeVector NetTranslation() const
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
HepRotation inverse() const
void DumpInfo() const
G4double GetMaxXExtent() const
G4double GetMinZExtent() const
G4bool IsLimited() const
bool G4bool
Definition: G4Types.hh:79
std::vector< G4ThreeVector > G4ThreeVectorList
Definition: G4VSolid.hh:79
HepGeom::Transform3D G4Transform3D
void G4Exception(const char *originOfException, const char *exceptionCode, G4ExceptionSeverity severity, const char *comments)
Definition: G4Exception.cc:41
G4RotationMatrix NetRotation() const
G4double GetMinXExtent() const
G4double GetMaxZExtent() const
G4double GetMaxYExtent() const
G4double kCarTolerance
Definition: G4VSolid.hh:305
double G4double
Definition: G4Types.hh:76
G4double GetMaxExtent(const EAxis pAxis) const
void ClipBetweenSections(G4ThreeVectorList *pVertices, const G4int pSectionIndex, const G4VoxelLimits &pVoxelLimit, const EAxis pAxis, G4double &pMin, G4double &pMax) const
Definition: G4VSolid.cc:378
G4double GetMinExtent(const EAxis pAxis) const
G4VSolid * G4ReflectedSolid::Clone ( ) const
virtual

Reimplemented from G4VSolid.

Definition at line 559 of file G4ReflectedSolid.cc.

References G4ReflectedSolid().

560 {
561  return new G4ReflectedSolid(*this);
562 }
G4ReflectedSolid(const G4String &pName, G4VSolid *pSolid, const G4Transform3D &transform)
void G4ReflectedSolid::ComputeDimensions ( G4VPVParameterisation *  p,
const G4int  n,
const G4VPhysicalVolume *  pRep 
)
virtual

Reimplemented from G4VSolid.

Definition at line 532 of file G4ReflectedSolid.cc.

References G4VSolid::DumpInfo(), FatalException, and G4Exception().

535 {
536  DumpInfo();
537  G4Exception("G4ReflectedSolid::ComputeDimensions()",
538  "GeomMgt0001", FatalException,
539  "Method not applicable in this context!");
540 }
void DumpInfo() const
void G4Exception(const char *originOfException, const char *exceptionCode, G4ExceptionSeverity severity, const char *comments)
Definition: G4Exception.cc:41
G4Polyhedron * G4ReflectedSolid::CreatePolyhedron ( ) const
virtual

Reimplemented from G4VSolid.

Definition at line 606 of file G4ReflectedSolid.cc.

References G4VSolid::CreatePolyhedron(), fDirectTransform3D, fPtrSolid, G4endl, G4Exception(), G4VSolid::GetName(), JustWarning, and HepPolyhedron::Transform().

Referenced by GetPolyhedron().

607 {
608  G4Polyhedron* polyhedron = fPtrSolid->CreatePolyhedron();
609  if (polyhedron)
610  {
611  polyhedron->Transform(*fDirectTransform3D);
612  return polyhedron;
613  }
614  else
615  {
616  std::ostringstream message;
617  message << "Solid - " << GetName()
618  << " - original solid has no" << G4endl
619  << "corresponding polyhedron. Returning NULL!";
620  G4Exception("G4ReflectedSolid::CreatePolyhedron()",
621  "GeomMgt1001", JustWarning, message);
622  return 0;
623  }
624 }
G4String GetName() const
HepPolyhedron & Transform(const G4Transform3D &t)
G4Transform3D * fDirectTransform3D
virtual G4Polyhedron * CreatePolyhedron() const
Definition: G4VSolid.cc:639
void G4Exception(const char *originOfException, const char *exceptionCode, G4ExceptionSeverity severity, const char *comments)
Definition: G4Exception.cc:41
#define G4endl
Definition: G4ios.hh:61
void G4ReflectedSolid::DescribeYourselfTo ( G4VGraphicsScene &  scene) const
virtual

Implements G4VSolid.

Definition at line 596 of file G4ReflectedSolid.cc.

References G4VGraphicsScene::AddSolid().

597 {
598  scene.AddSolid (*this);
599 }
virtual void AddSolid(const G4Box &)=0
G4double G4ReflectedSolid::DistanceToIn ( const G4ThreeVector &  p,
const G4ThreeVector &  v 
) const
virtual

Implements G4VSolid.

Definition at line 460 of file G4ReflectedSolid.cc.

References G4VSolid::DistanceToIn(), fPtrSolid, HepGeom::BasicVector3D< T >::unit(), HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

462 {
463  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p) ;
464  G4Point3D newDirection = (*fDirectTransform3D)*G4Point3D(v) ;
465  newDirection.unit() ;
466  return fPtrSolid->DistanceToIn(
467  G4ThreeVector(newPoint.x(),newPoint.y(),newPoint.z()),
468  G4ThreeVector(newDirection.x(),newDirection.y(),newDirection.z())) ;
469 }
CLHEP::Hep3Vector G4ThreeVector
BasicVector3D< T > unit() const
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
virtual G4double DistanceToIn(const G4ThreeVector &p, const G4ThreeVector &v) const =0
G4double G4ReflectedSolid::DistanceToIn ( const G4ThreeVector &  p) const
virtual

Implements G4VSolid.

Definition at line 477 of file G4ReflectedSolid.cc.

References G4VSolid::DistanceToIn(), fPtrSolid, HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

478 {
479  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p) ;
480  return fPtrSolid->DistanceToIn(
481  G4ThreeVector(newPoint.x(),newPoint.y(),newPoint.z())) ;
482 }
CLHEP::Hep3Vector G4ThreeVector
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
virtual G4double DistanceToIn(const G4ThreeVector &p, const G4ThreeVector &v) const =0
G4double G4ReflectedSolid::DistanceToOut ( const G4ThreeVector &  p,
const G4ThreeVector &  v,
const G4bool  calcNorm = false,
G4bool *  validNorm = 0,
G4ThreeVector *  n = 0 
) const
virtual

Implements G4VSolid.

Definition at line 489 of file G4ReflectedSolid.cc.

References G4VSolid::DistanceToOut(), fPtrSolid, HepGeom::BasicVector3D< T >::unit(), HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

494 {
495  G4ThreeVector solNorm ;
496 
497  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p) ;
498  G4Point3D newDirection = (*fDirectTransform3D)*G4Point3D(v);
499  newDirection.unit() ;
500 
501  G4double dist =
503  G4ThreeVector(newPoint.x(),newPoint.y(),newPoint.z()),
504  G4ThreeVector(newDirection.x(),newDirection.y(),newDirection.z()),
505  calcNorm, validNorm, &solNorm) ;
506  if(calcNorm)
507  {
508  G4Point3D newN = (*fDirectTransform3D)*G4Point3D(solNorm);
509  newN.unit() ;
510  *n = G4ThreeVector(newN.x(),newN.y(),newN.z());
511  }
512  return dist ;
513 }
CLHEP::Hep3Vector G4ThreeVector
BasicVector3D< T > unit() const
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
double G4double
Definition: G4Types.hh:76
virtual G4double DistanceToOut(const G4ThreeVector &p, const G4ThreeVector &v, const G4bool calcNorm=false, G4bool *validNorm=0, G4ThreeVector *n=0) const =0
G4double G4ReflectedSolid::DistanceToOut ( const G4ThreeVector &  p) const
virtual

Implements G4VSolid.

Definition at line 520 of file G4ReflectedSolid.cc.

References G4VSolid::DistanceToOut(), fPtrSolid, HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

521 {
522  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p);
523  return fPtrSolid->DistanceToOut(
524  G4ThreeVector(newPoint.x(),newPoint.y(),newPoint.z()));
525 }
CLHEP::Hep3Vector G4ThreeVector
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
virtual G4double DistanceToOut(const G4ThreeVector &p, const G4ThreeVector &v, const G4bool calcNorm=false, G4bool *validNorm=0, G4ThreeVector *n=0) const =0
G4VSolid * G4ReflectedSolid::GetConstituentMovedSolid ( ) const

Definition at line 150 of file G4ReflectedSolid.cc.

References fPtrSolid.

Referenced by G4tgbGeometryDumper::DumpSolid().

151 {
152  return fPtrSolid;
153 }
G4AffineTransform G4ReflectedSolid::GetDirectTransform ( ) const
protected

Definition at line 171 of file G4ReflectedSolid.cc.

References fDirectTransform.

172 {
173  G4AffineTransform aTransform= *fDirectTransform;
174  return aTransform;
175 }
G4AffineTransform * fDirectTransform
G4Transform3D G4ReflectedSolid::GetDirectTransform3D ( ) const

Definition at line 199 of file G4ReflectedSolid.cc.

References fDirectTransform3D.

200 {
201  G4Transform3D aTransform= *fDirectTransform3D;
202  return aTransform;
203 }
G4Transform3D * fDirectTransform3D
G4GeometryType G4ReflectedSolid::GetEntityType ( ) const
virtual

Implements G4VSolid.

Definition at line 135 of file G4ReflectedSolid.cc.

Referenced by StreamInfo().

136 {
137  return G4String("G4ReflectedSolid");
138 }
G4RotationMatrix G4ReflectedSolid::GetFrameRotation ( ) const
protected

Definition at line 213 of file G4ReflectedSolid.cc.

References fDirectTransform, and G4AffineTransform::NetRotation().

214 {
216  return InvRotation;
217 }
G4AffineTransform * fDirectTransform
G4RotationMatrix NetRotation() const
G4ThreeVector G4ReflectedSolid::GetFrameTranslation ( ) const
protected

Definition at line 226 of file G4ReflectedSolid.cc.

References fPtrTransform, and G4AffineTransform::NetTranslation().

227 {
228  return fPtrTransform->NetTranslation();
229 }
G4ThreeVector NetTranslation() const
G4AffineTransform * fPtrTransform
G4RotationMatrix G4ReflectedSolid::GetObjectRotation ( ) const
protected

Definition at line 238 of file G4ReflectedSolid.cc.

References fPtrTransform, and G4AffineTransform::NetRotation().

239 {
241  return Rotation;
242 }
G4RotationMatrix NetRotation() const
G4AffineTransform * fPtrTransform
G4ThreeVector G4ReflectedSolid::GetObjectTranslation ( ) const
protected

Definition at line 251 of file G4ReflectedSolid.cc.

References fDirectTransform, and G4AffineTransform::NetTranslation().

252 {
254 }
G4ThreeVector NetTranslation() const
G4AffineTransform * fDirectTransform
G4ThreeVector G4ReflectedSolid::GetPointOnSurface ( ) const
virtual

Reimplemented from G4VSolid.

Definition at line 547 of file G4ReflectedSolid.cc.

References fPtrSolid, G4VSolid::GetPointOnSurface(), HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

548 {
550  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p);
551 
552  return G4ThreeVector(newPoint.x(),newPoint.y(),newPoint.z());
553 }
CLHEP::Hep3Vector G4ThreeVector
const char * p
Definition: xmltok.h:285
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
virtual G4ThreeVector GetPointOnSurface() const
Definition: G4VSolid.cc:152
G4Polyhedron * G4ReflectedSolid::GetPolyhedron ( ) const
virtual

Reimplemented from G4VSolid.

Definition at line 631 of file G4ReflectedSolid.cc.

References CreatePolyhedron(), fpPolyhedron, HepPolyhedron::GetNumberOfRotationSteps(), and G4Polyhedron::GetNumberOfRotationStepsAtTimeOfCreation().

632 {
633  if (!fpPolyhedron ||
636  {
637  delete fpPolyhedron;
639  }
640  return fpPolyhedron;
641 }
static G4int GetNumberOfRotationSteps()
G4Polyhedron * fpPolyhedron
G4int GetNumberOfRotationStepsAtTimeOfCreation() const
G4Polyhedron * CreatePolyhedron() const
const G4ReflectedSolid * G4ReflectedSolid::GetReflectedSolidPtr ( ) const
virtual

Definition at line 140 of file G4ReflectedSolid.cc.

141 {
142  return this;
143 }
G4ReflectedSolid * G4ReflectedSolid::GetReflectedSolidPtr ( )
virtual

Definition at line 145 of file G4ReflectedSolid.cc.

146 {
147  return this;
148 }
G4AffineTransform G4ReflectedSolid::GetTransform ( ) const
protected

Definition at line 157 of file G4ReflectedSolid.cc.

References fPtrTransform.

158 {
159  G4AffineTransform aTransform = *fPtrTransform;
160  return aTransform;
161 }
G4AffineTransform * fPtrTransform
G4Transform3D G4ReflectedSolid::GetTransform3D ( ) const

Definition at line 185 of file G4ReflectedSolid.cc.

References fPtrTransform3D.

186 {
187  G4Transform3D aTransform = *fPtrTransform3D;
188  return aTransform;
189 }
G4Transform3D * fPtrTransform3D
EInside G4ReflectedSolid::Inside ( const G4ThreeVector &  p) const
virtual

Implements G4VSolid.

Definition at line 426 of file G4ReflectedSolid.cc.

References fPtrSolid, G4VSolid::Inside(), HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

Referenced by CalculateExtent().

427 {
428 
429  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p) ;
430  // G4Point3D newPoint = (*fPtrTransform3D)*G4Point3D(p) ;
431 
432  return fPtrSolid->Inside(G4ThreeVector(newPoint.x(),
433  newPoint.y(),
434  newPoint.z())) ;
435 }
CLHEP::Hep3Vector G4ThreeVector
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
virtual EInside Inside(const G4ThreeVector &p) const =0
G4ReflectedSolid & G4ReflectedSolid::operator= ( const G4ReflectedSolid &  rhs)

Definition at line 107 of file G4ReflectedSolid.cc.

References fDirectTransform, fDirectTransform3D, fpPolyhedron, fPtrSolid, fPtrTransform, fPtrTransform3D, and G4VSolid::operator=().

108 {
109  // Check assignment to self
110  //
111  if (this == &rhs) { return *this; }
112 
113  // Copy base class data
114  //
115  G4VSolid::operator=(rhs);
116 
117  // Copy data
118  //
120  delete fPtrTransform;
122  delete fDirectTransform;
124  delete fPtrTransform3D;
126  delete fDirectTransform3D;
128 
129  return *this;
130 }
G4Transform3D * fDirectTransform3D
G4AffineTransform * fDirectTransform
G4Transform3D * fPtrTransform3D
HepGeom::Transform3D G4Transform3D
G4AffineTransform * fPtrTransform
G4Polyhedron * fpPolyhedron
G4VSolid & operator=(const G4VSolid &rhs)
Definition: G4VSolid.cc:110
void G4ReflectedSolid::SetDirectTransform ( G4AffineTransform &  transform)
protected

Definition at line 177 of file G4ReflectedSolid.cc.

References fDirectTransform, and fpPolyhedron.

178 {
179  fDirectTransform = &transform ;
180  fpPolyhedron = 0;
181 }
G4AffineTransform * fDirectTransform
G4Polyhedron * fpPolyhedron
void G4ReflectedSolid::SetDirectTransform3D ( G4Transform3D &  transform)

Definition at line 205 of file G4ReflectedSolid.cc.

References fDirectTransform3D, and fpPolyhedron.

206 {
207  fDirectTransform3D = &transform ;
208  fpPolyhedron = 0;
209 }
G4Transform3D * fDirectTransform3D
G4Polyhedron * fpPolyhedron
void G4ReflectedSolid::SetFrameRotation ( const G4RotationMatrix &  matrix)
protected

Definition at line 219 of file G4ReflectedSolid.cc.

References fDirectTransform, and G4AffineTransform::SetNetRotation().

220 {
222 }
G4AffineTransform * fDirectTransform
void SetNetRotation(const G4RotationMatrix &rot)
void G4ReflectedSolid::SetFrameTranslation ( const G4ThreeVector &  vector)
protected

Definition at line 231 of file G4ReflectedSolid.cc.

References fPtrTransform, and G4AffineTransform::SetNetTranslation().

232 {
234 }
void SetNetTranslation(const G4ThreeVector &tlate)
G4AffineTransform * fPtrTransform
void G4ReflectedSolid::SetObjectRotation ( const G4RotationMatrix &  matrix)
protected

Definition at line 244 of file G4ReflectedSolid.cc.

References fPtrTransform, and G4AffineTransform::SetNetRotation().

245 {
246  fPtrTransform->SetNetRotation(matrix);
247 }
void SetNetRotation(const G4RotationMatrix &rot)
G4AffineTransform * fPtrTransform
void G4ReflectedSolid::SetObjectTranslation ( const G4ThreeVector &  vector)
protected

Definition at line 256 of file G4ReflectedSolid.cc.

References fDirectTransform, and G4AffineTransform::SetNetTranslation().

257 {
259 }
G4AffineTransform * fDirectTransform
void SetNetTranslation(const G4ThreeVector &tlate)
void G4ReflectedSolid::SetTransform ( G4AffineTransform &  transform)
protected

Definition at line 163 of file G4ReflectedSolid.cc.

References fpPolyhedron, and fPtrTransform.

164 {
165  fPtrTransform = &transform ;
166  fpPolyhedron = 0;
167 }
G4AffineTransform * fPtrTransform
G4Polyhedron * fpPolyhedron
void G4ReflectedSolid::SetTransform3D ( G4Transform3D &  transform)

Definition at line 191 of file G4ReflectedSolid.cc.

References fpPolyhedron, and fPtrTransform3D.

192 {
193  fPtrTransform3D = &transform ;
194  fpPolyhedron = 0;
195 }
G4Transform3D * fPtrTransform3D
G4Polyhedron * fpPolyhedron
std::ostream & G4ReflectedSolid::StreamInfo ( std::ostream &  os) const
virtual

Implements G4VSolid.

Definition at line 569 of file G4ReflectedSolid.cc.

References fDirectTransform, fPtrSolid, GetEntityType(), G4VSolid::GetName(), G4AffineTransform::NetRotation(), G4AffineTransform::NetTranslation(), CLHEP::HepRotation::print(), and G4VSolid::StreamInfo().

570 {
571  os << "-----------------------------------------------------------\n"
572  << " *** Dump for Reflected solid - " << GetName() << " ***\n"
573  << " ===================================================\n"
574  << " Solid type: " << GetEntityType() << "\n"
575  << " Parameters of constituent solid: \n"
576  << "===========================================================\n";
577  fPtrSolid->StreamInfo(os);
578  os << "===========================================================\n"
579  << " Transformations: \n"
580  << " Direct transformation - translation : \n"
581  << " " << fDirectTransform->NetTranslation() << "\n"
582  << " - rotation : \n"
583  << " ";
585  os << "\n"
586  << "===========================================================\n";
587 
588  return os;
589 }
G4String GetName() const
std::ostream & print(std::ostream &os) const
Definition: RotationIO.cc:21
G4ThreeVector NetTranslation() const
G4AffineTransform * fDirectTransform
virtual std::ostream & StreamInfo(std::ostream &os) const =0
virtual G4GeometryType GetEntityType() const
G4RotationMatrix NetRotation() const
G4ThreeVector G4ReflectedSolid::SurfaceNormal ( const G4ThreeVector &  p) const
virtual

Implements G4VSolid.

Definition at line 442 of file G4ReflectedSolid.cc.

References fPtrSolid, G4VSolid::SurfaceNormal(), HepGeom::BasicVector3D< T >::unit(), HepGeom::BasicVector3D< T >::x(), HepGeom::BasicVector3D< T >::y(), and HepGeom::BasicVector3D< T >::z().

443 {
444  G4Point3D newPoint = (*fDirectTransform3D)*G4Point3D(p) ;
445  G4ThreeVector normal =
447  newPoint.y(),
448  newPoint.z() ) ) ;
449  G4Point3D newN = (*fDirectTransform3D)*G4Point3D(normal) ;
450  newN.unit() ;
451 
452  return G4ThreeVector(newN.x(),newN.y(),newN.z()) ;
453 }
CLHEP::Hep3Vector G4ThreeVector
BasicVector3D< T > unit() const
HepGeom::Point3D< G4double > G4Point3D
Definition: G4Point3D.hh:35
virtual G4ThreeVector SurfaceNormal(const G4ThreeVector &p) const =0

Field Documentation

G4AffineTransform* G4ReflectedSolid::fDirectTransform
protected
G4Transform3D* G4ReflectedSolid::fDirectTransform3D
protected
G4Polyhedron* G4ReflectedSolid::fpPolyhedron
mutableprotected
G4VSolid* G4ReflectedSolid::fPtrSolid
protected
G4AffineTransform* G4ReflectedSolid::fPtrTransform
protected
G4Transform3D* G4ReflectedSolid::fPtrTransform3D
protected

The documentation for this class was generated from the following files: